
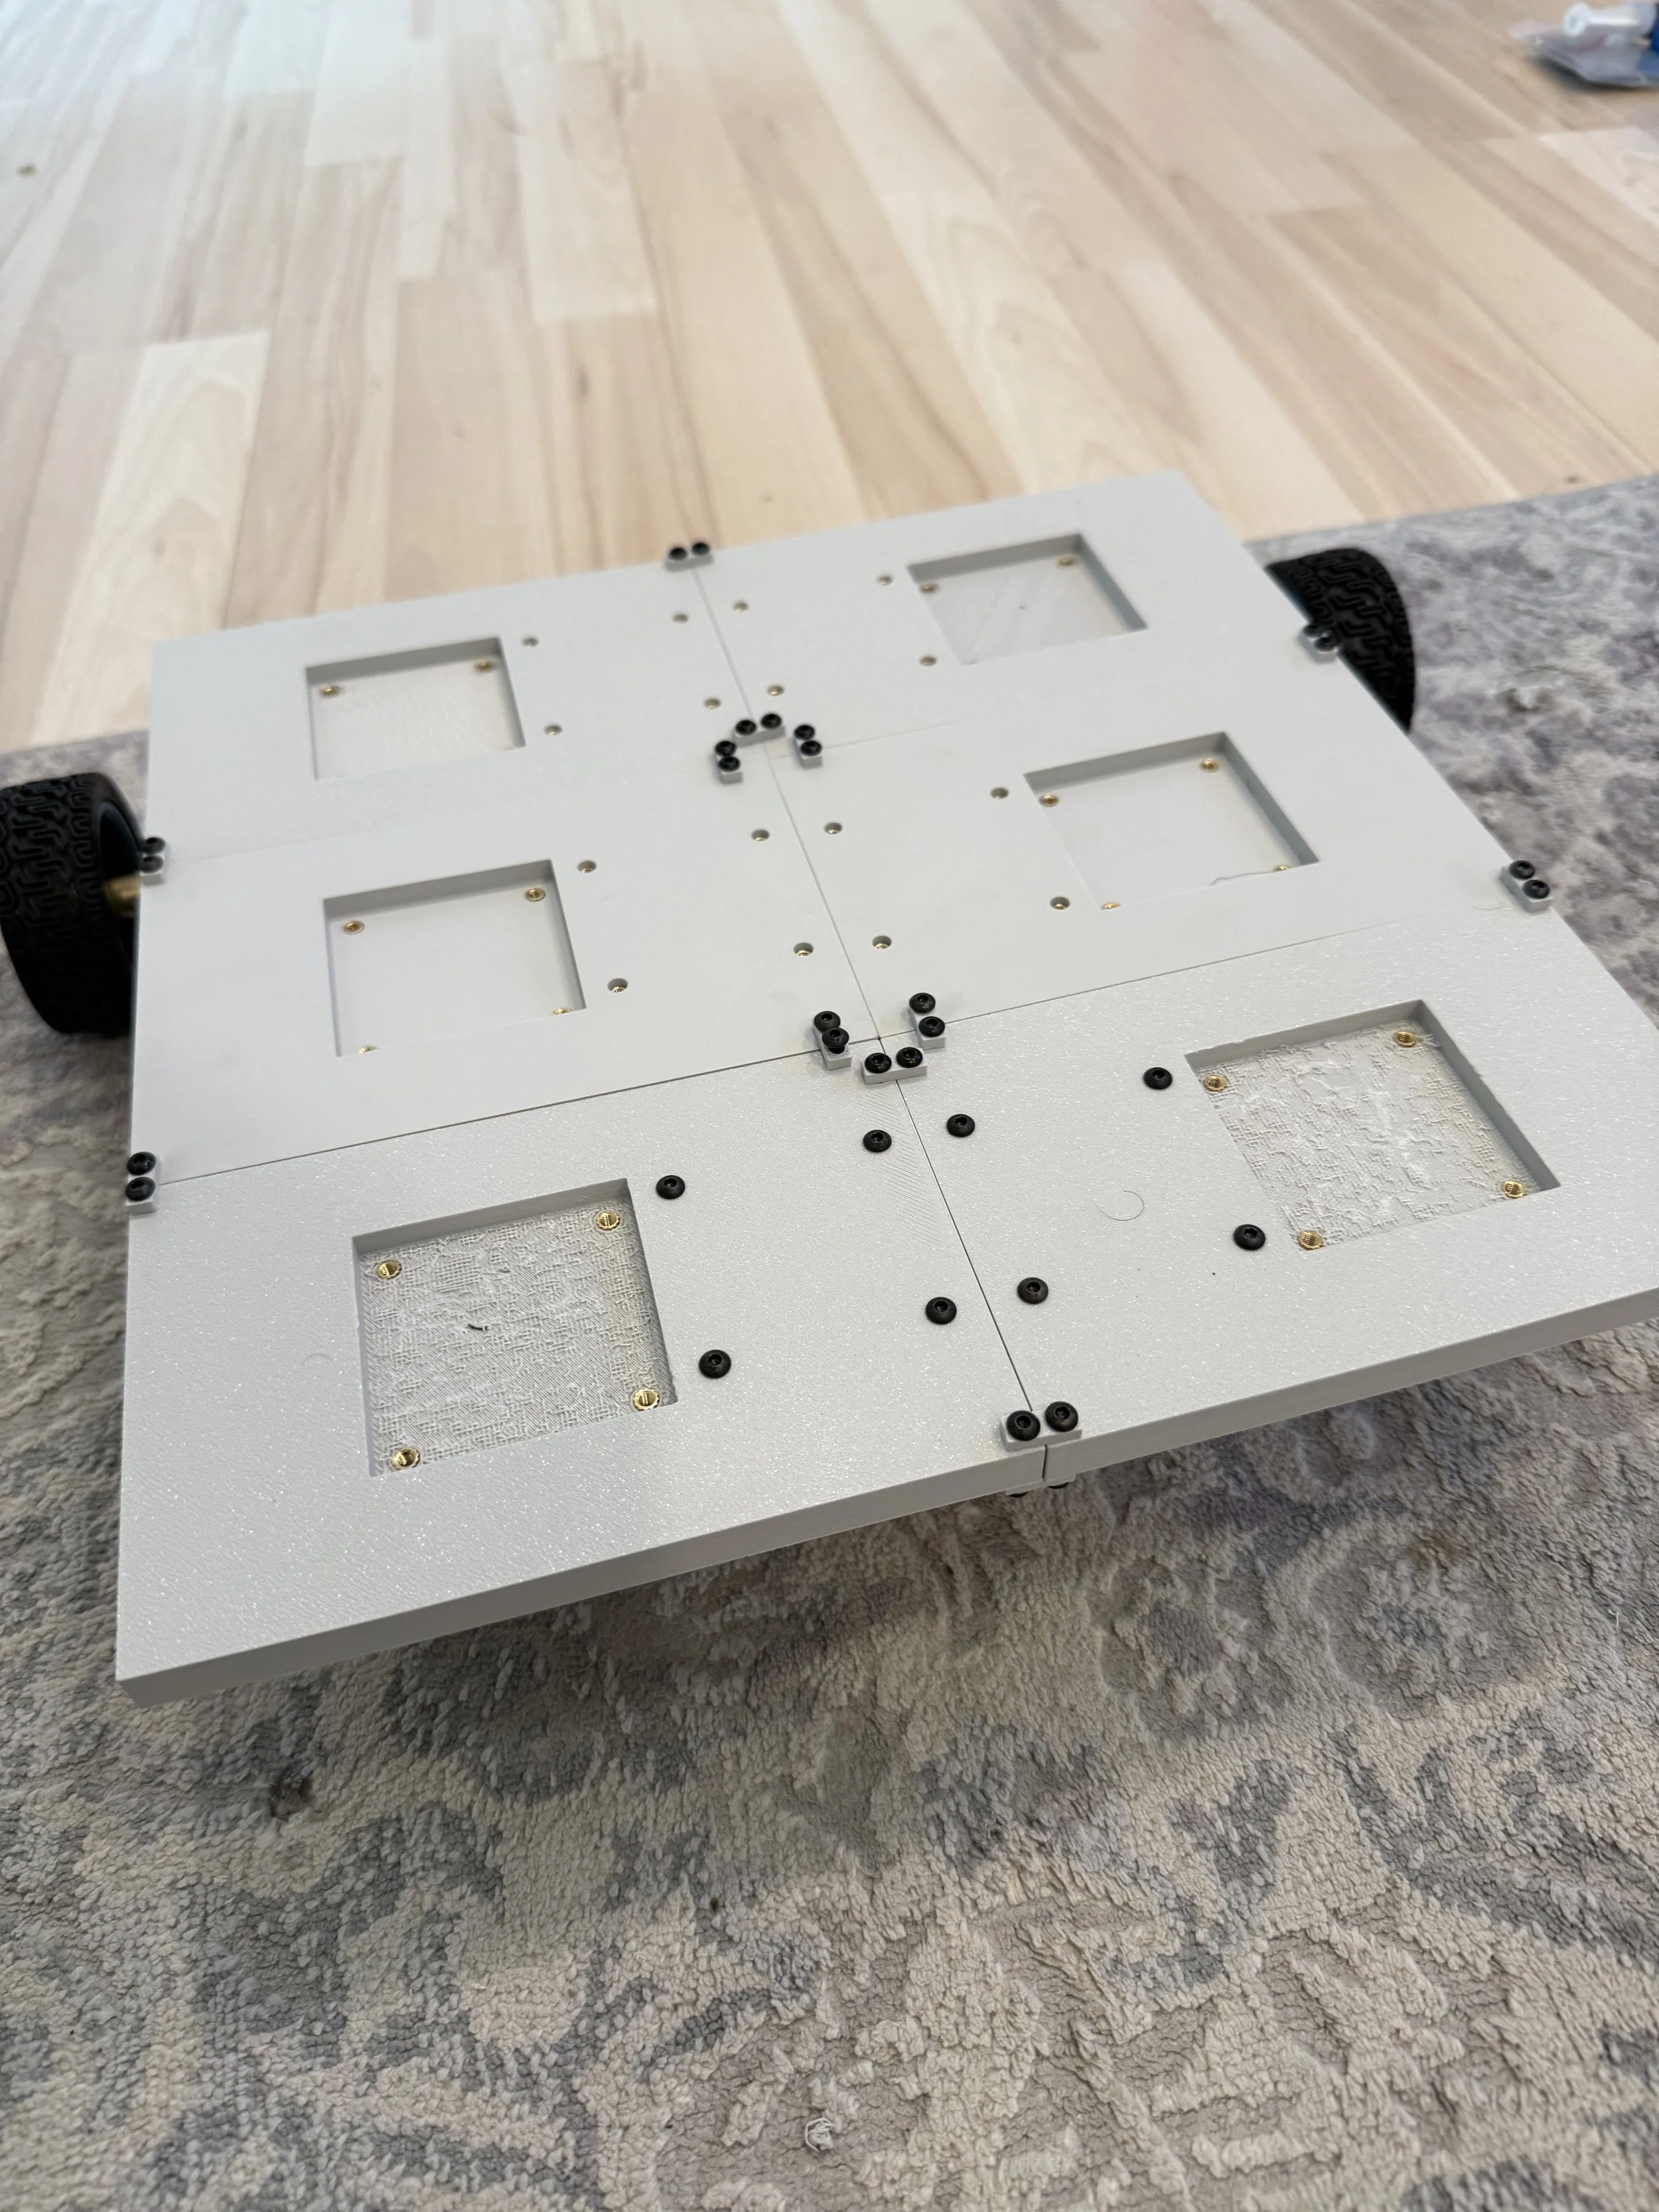
A look into our creative world.
Explore a curated collection of projects that showcase our journey from foundational robotics to advanced AI systems. Each project reflects our commitment to building intelligent machines while inspiring the next generation of engineers.
From quadruped locomotion to autonomous navigation, from computer vision to multi-agent AI—every robot here represents a solved challenge, a new capability tested in the real world, and a learning moment shared with students and makers.
Our portfolio proves that great robotics isn't just about the final product. It's about understanding the process: how to think through problems, build methodically, test rigorously, and iterate relentlessly. That philosophy drives everything we build and everything we teach.
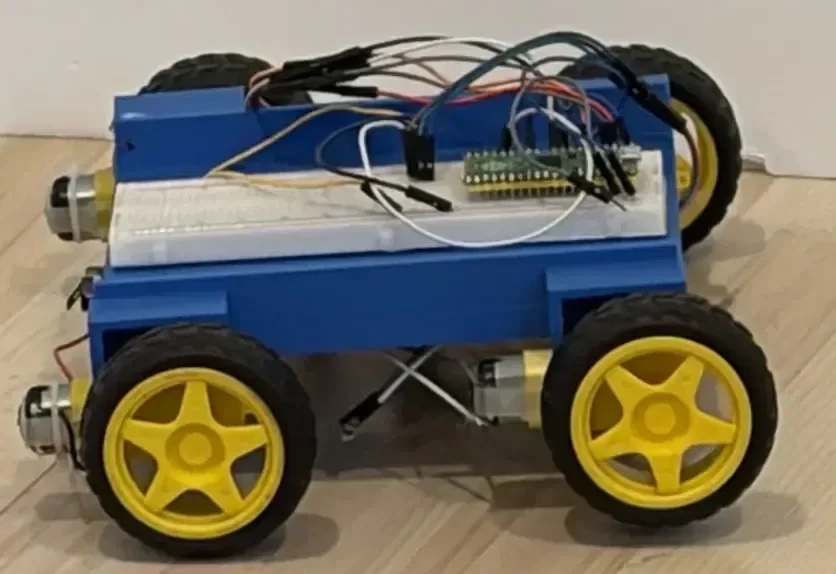
Autonomous Navigator V1:
Age 10 project. Arduino/RPi Pico-based autonomous gripper with limit switch control. Modular M3 brass design that teaches fundamental servo mechanics and autonomous decision-making.
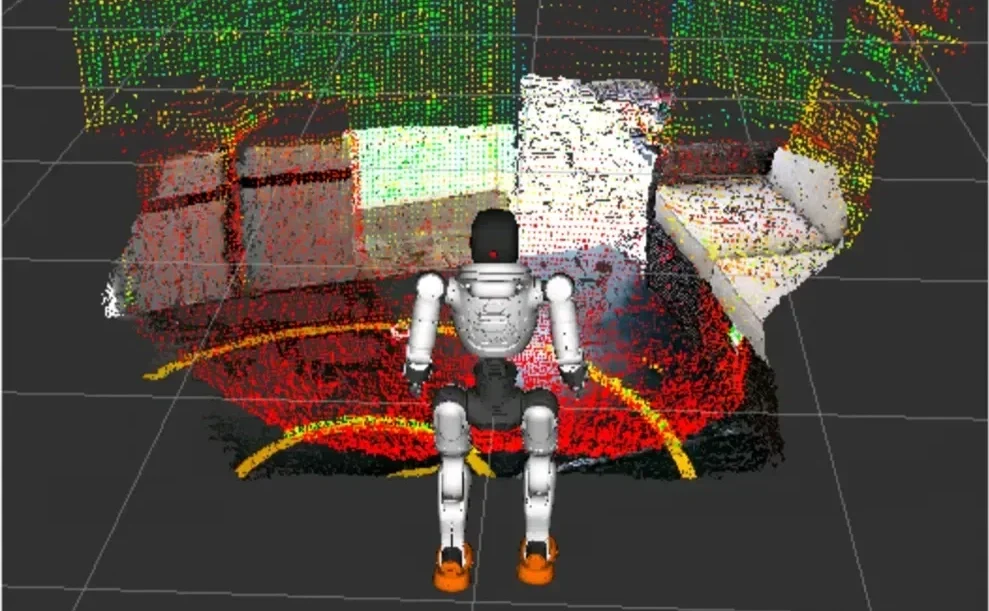
Agibot Obstacle Avoidance:
Added obstacle detection and teleoperation software to pre-built 30-DOF humanoid. Built sensor fusion pipeline, ROS2 visualization, and spoken warning system for safe autonomous operation.
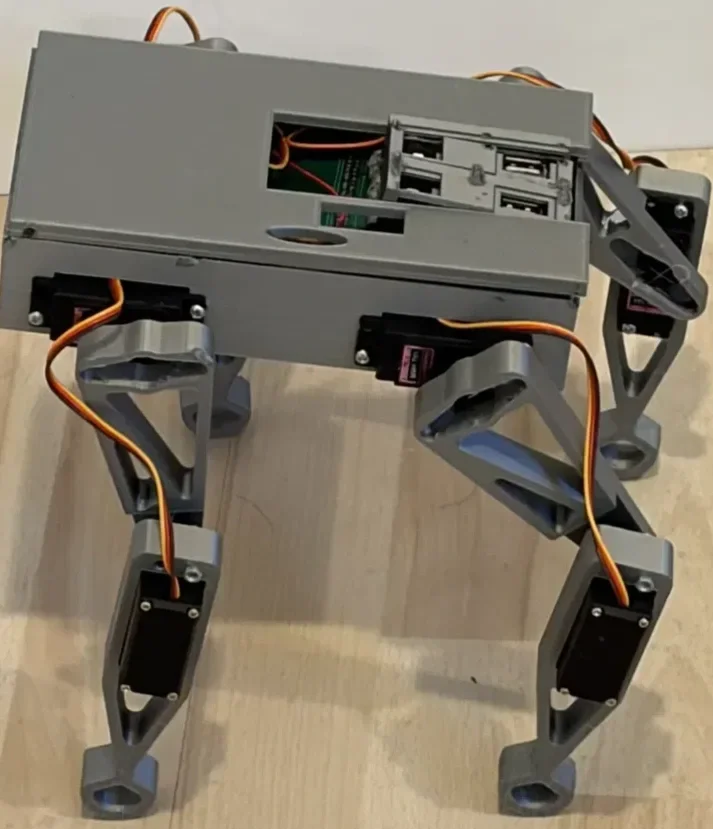
ODIE V2:
Refined servo control and ROS2 simulation in Gazebo—proved the gait algorithms work before building v3.
Homecell V1:
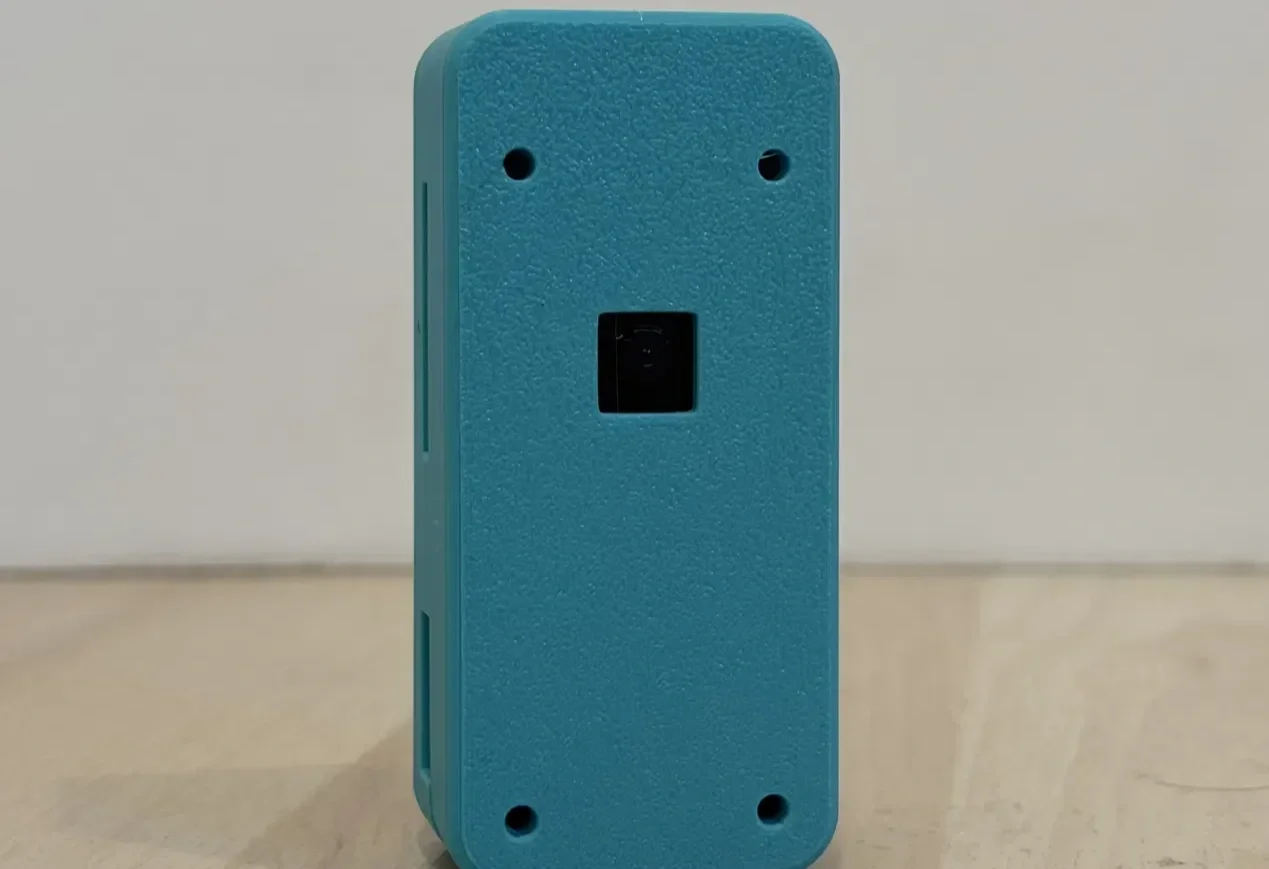
Smart security system on Raspberry Pi Zero 2W. Real-time object detection identifies people in rooms, sends alerts via Flask web dashboard. Demonstrates IoT implementation of computer vision for home monitoring.
TORQUE V1:
Tactical Operations & Robotics Quantum Utility Engine—a multi-language compiler system that switches between Python, Java, and C/C++ for flexible robotics development on Jetson platforms.
Sweeper V1
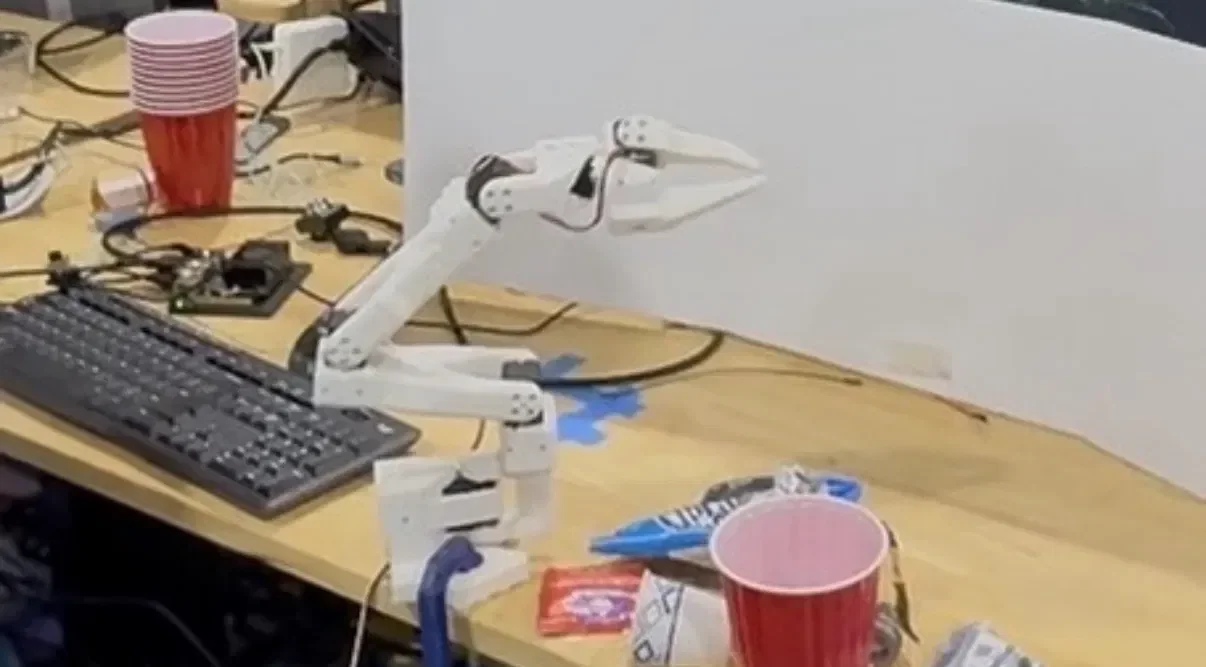
ACT model with lightweight VLA trained on Hugging Face using eGPUs. Combines YOLO person detection with autonomous desk-sweeping behavior—stops when humans nearby. Trained to sweep trash into trash cans below.
ALFRID V2:
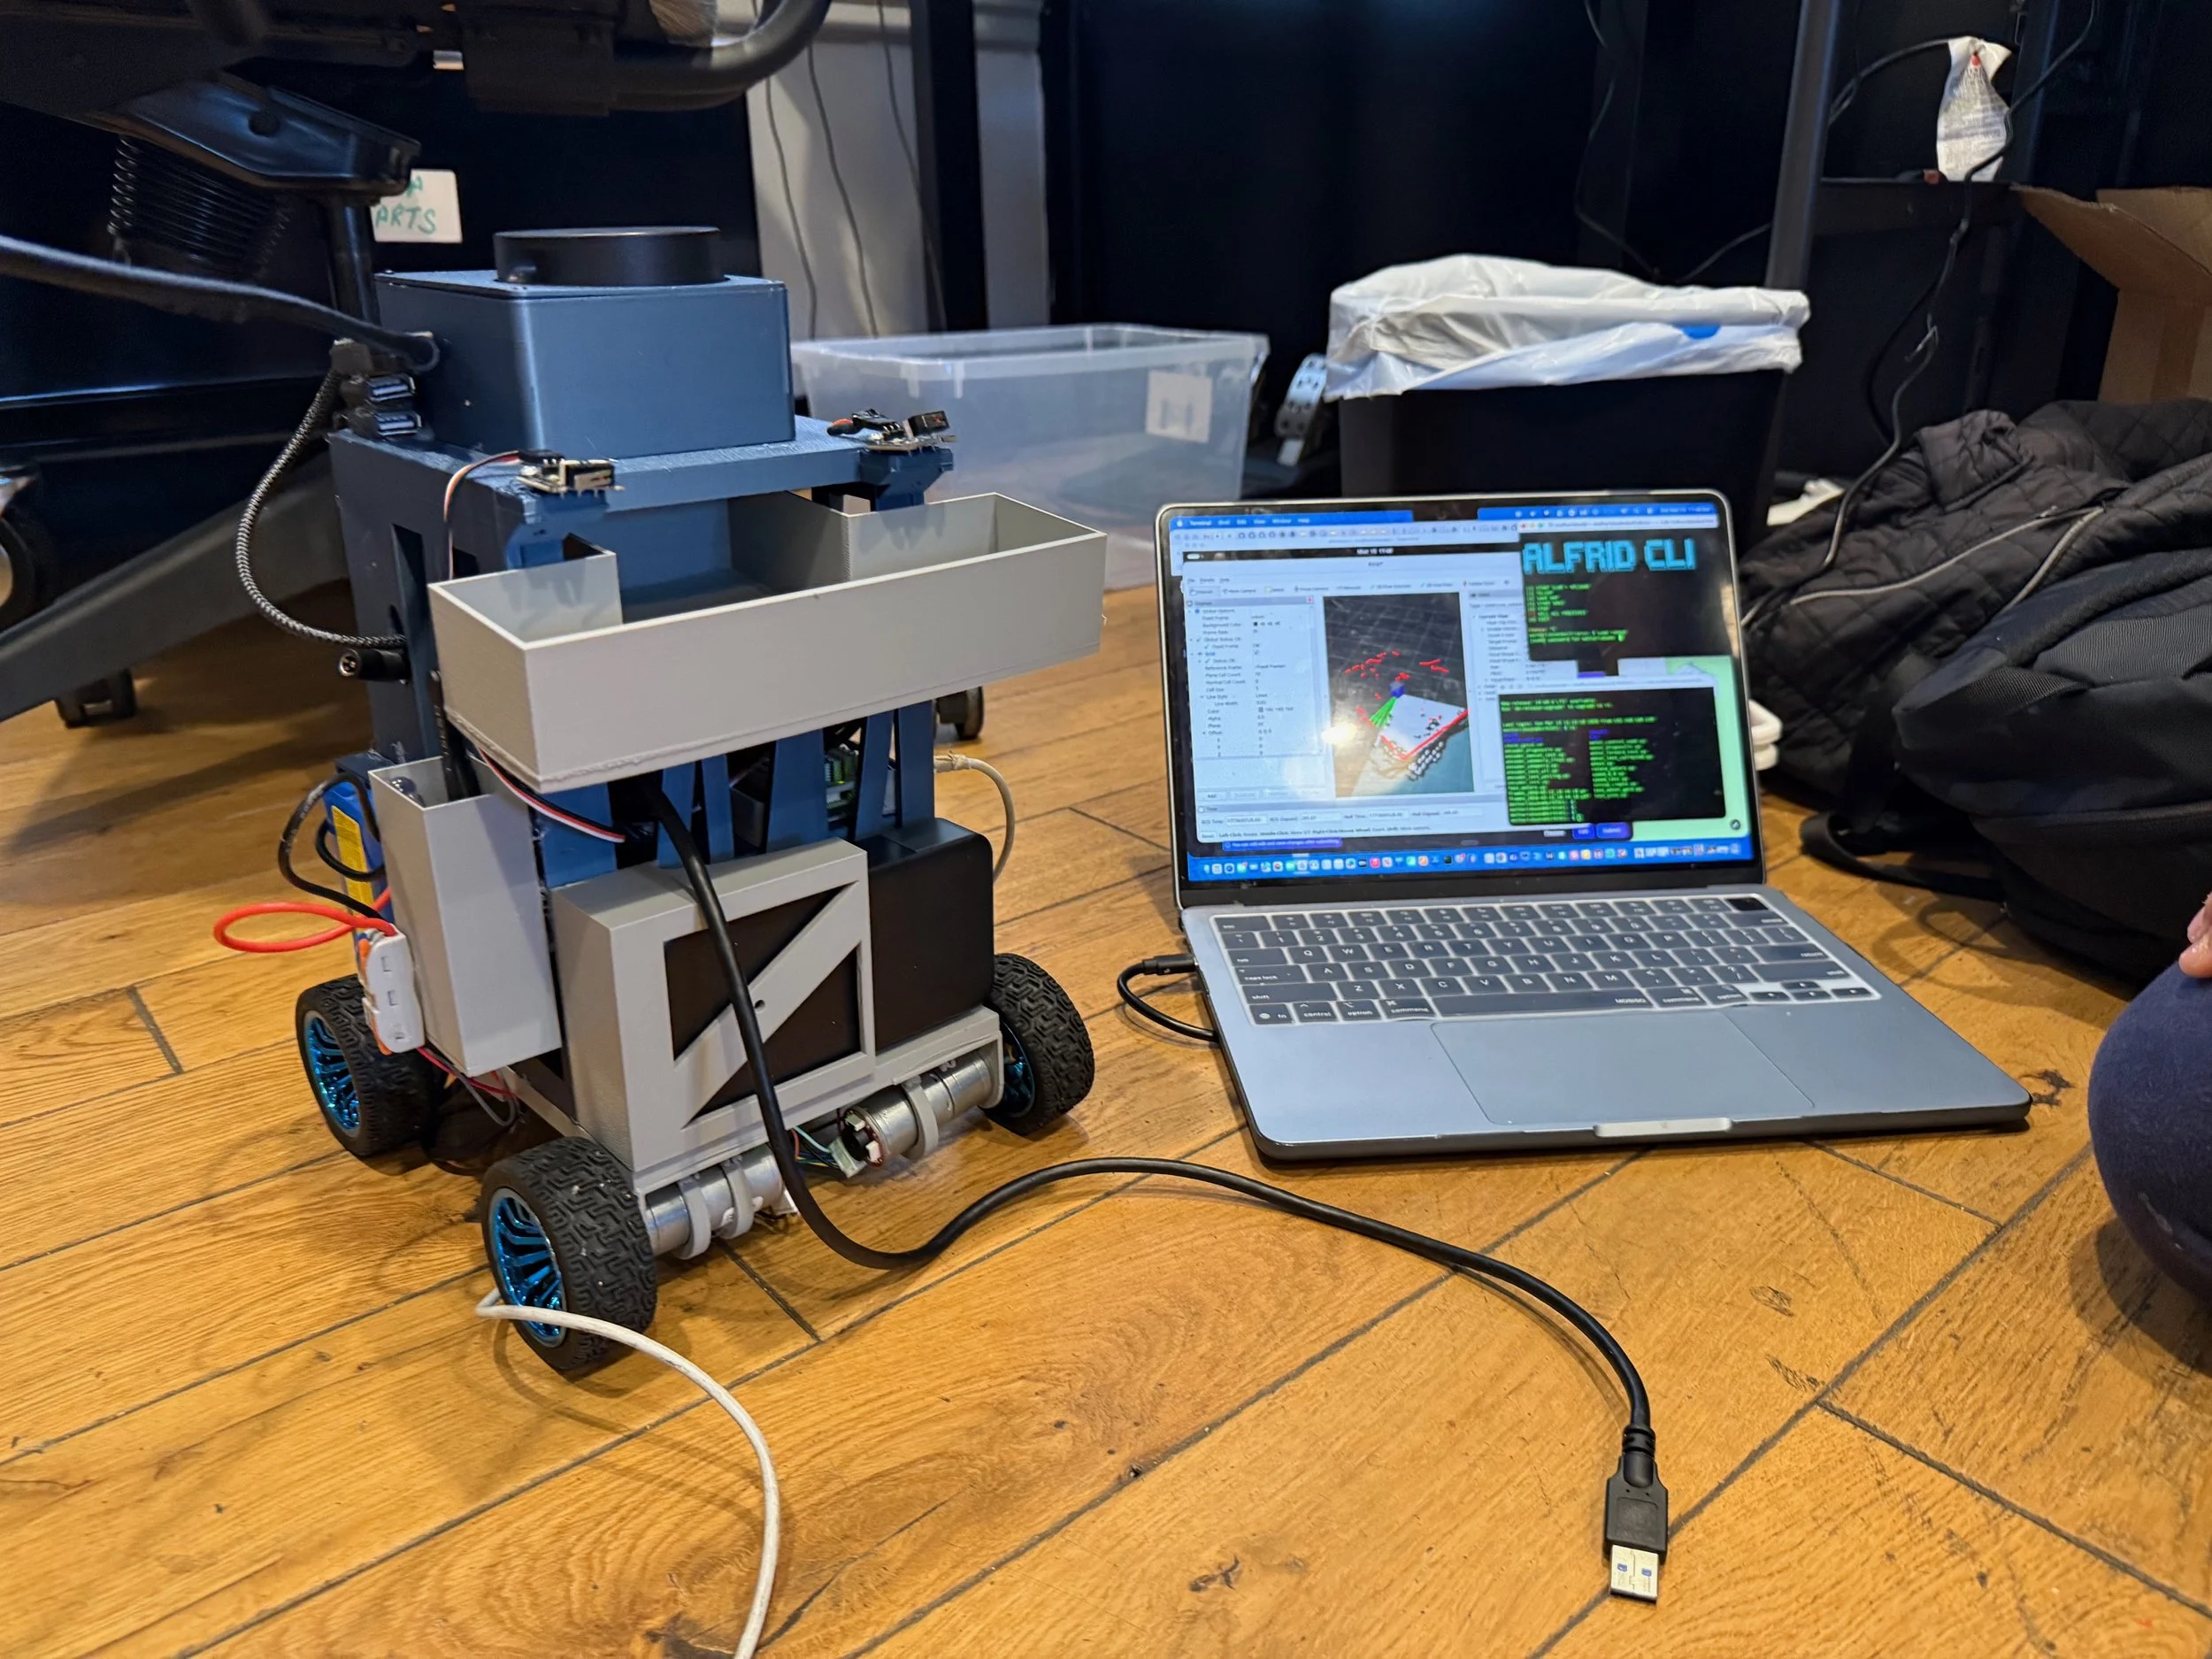
Refined wheeled platform with RPLidar sensor integration for 360-degree environmental scanning. Implemented real-time obstacle detection and dynamic steering algorithms so the robot could navigate around obstacles instead of bumping into them. Proved autonomous navigation with responsive obstacle avoidance works on a budget platform.
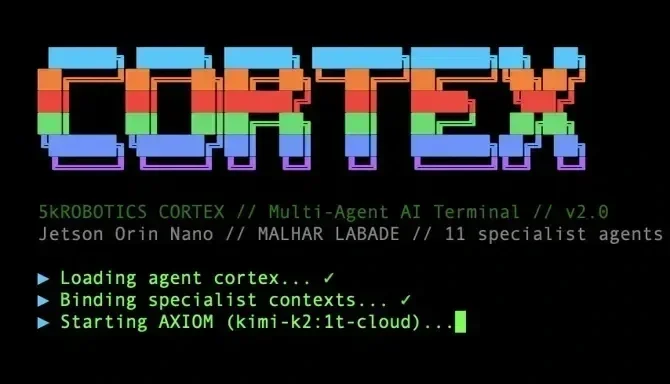
CORTEX V1:
Multi-agent AI terminal on Jetson Orin Nano with 11 specialist agents. Switch between agents by typing their name—each one specialized for a different robotics challenge, from mechanical design to vision systems to competition strategy.
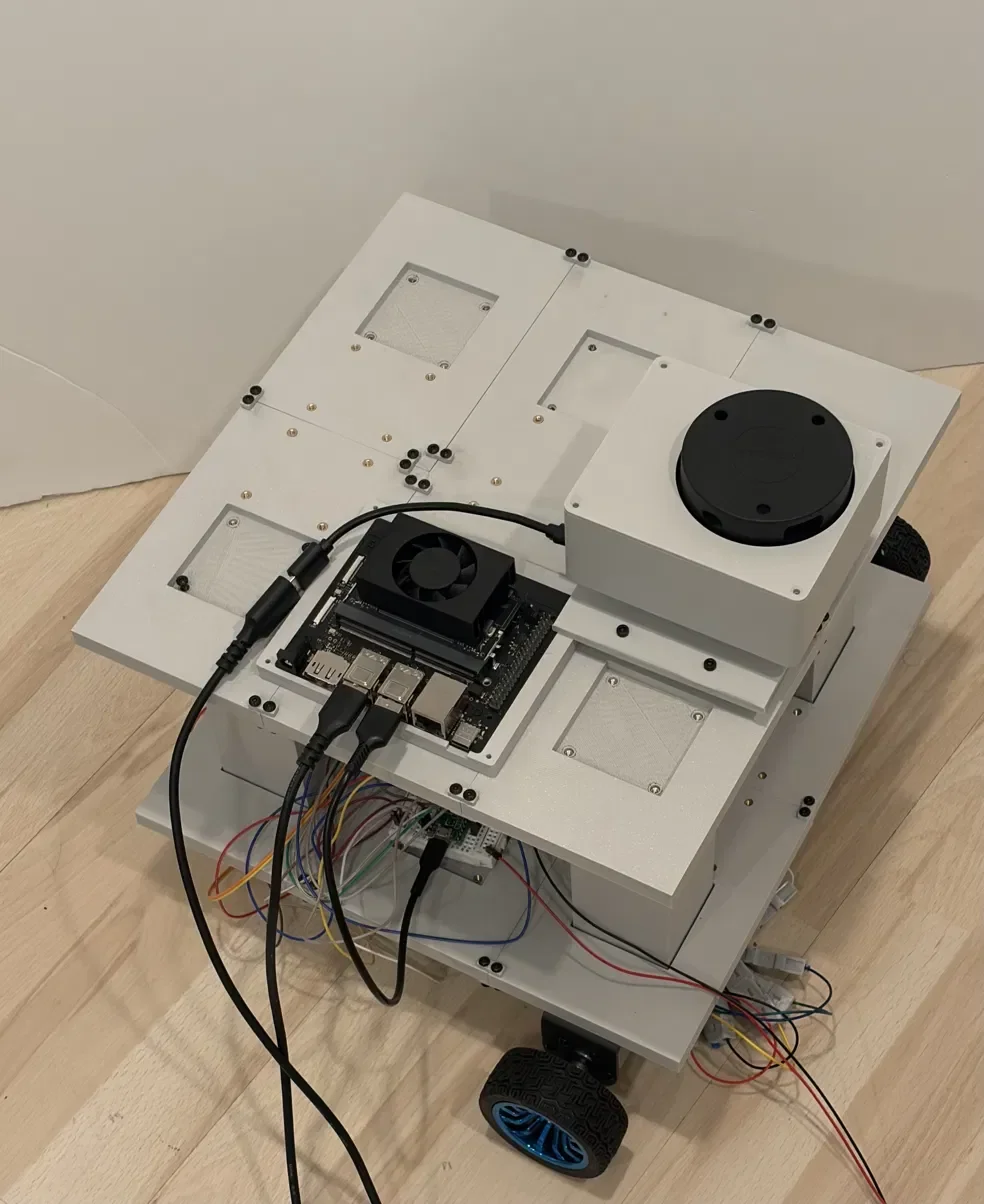
ALFRID V3:
Jetson Orin Nano + ROS2 SLAM + Nav2—the full autonomous navigation platform that actually ships and solves real problems.
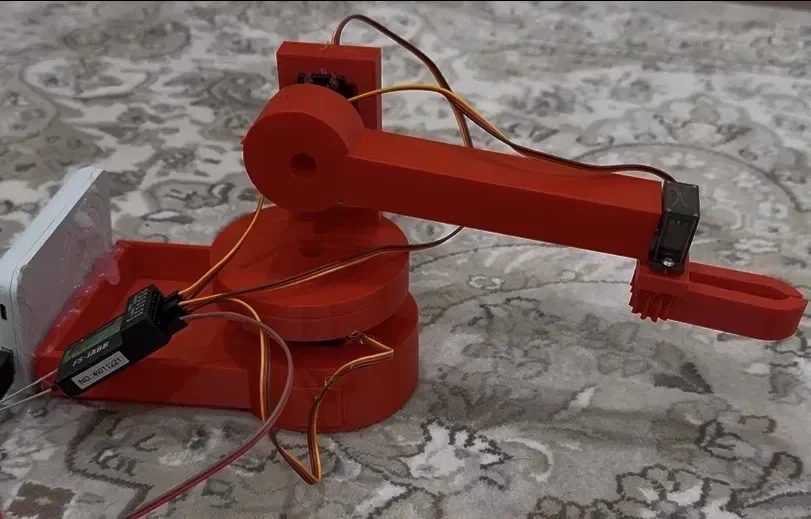
Camp Arm 2025 V1:
A 3-potentiometer controlled robotic hand built and taught at 2025 camp. Students learn servo control, mechanical linkages, and real-time input mapping through hands-on assembly and programming.
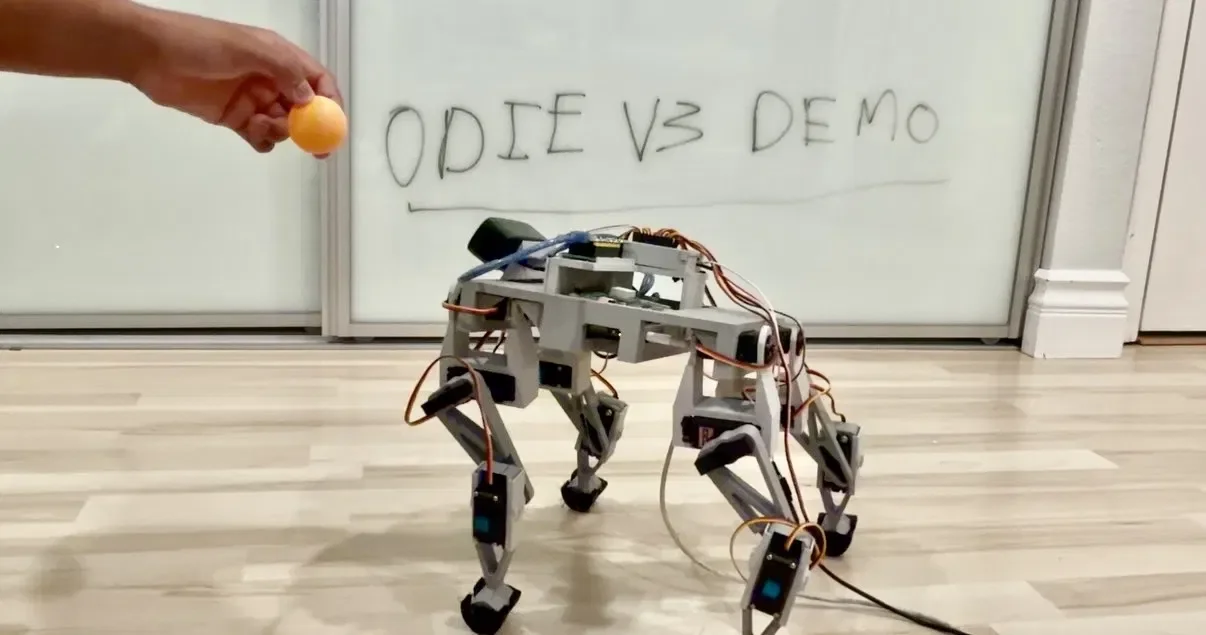
ODIE V3
Advanced trot diagonal gait with refined servo control—the quadruped that actually walks. Trained with reinforcement learning to optimize motion and balance across different terrains.
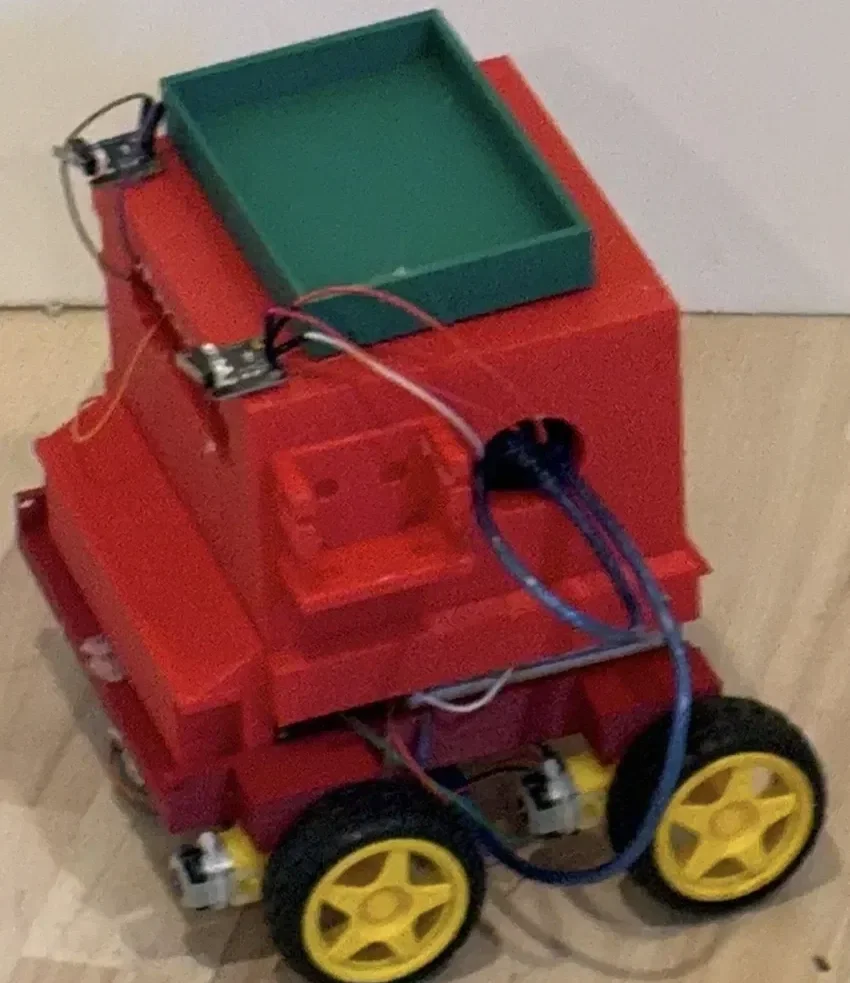
ALFRID V1:
Simple, janky proof of concept that proved wheeled autonomous movement works—the messy foundation everything else is built on. It uses the Autonomous Navigator’s base as a way to navigate autonomously.
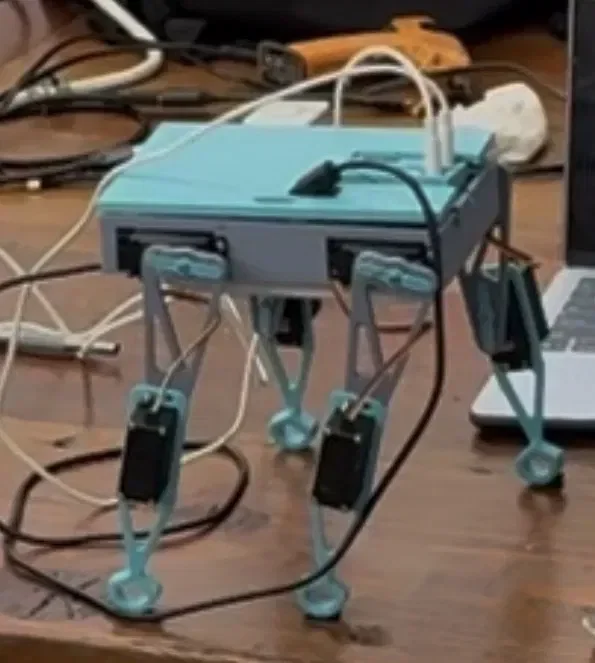
ODIE V1:
First quadruped platform that proved servo-based locomotion works—foundation for everything that came after.
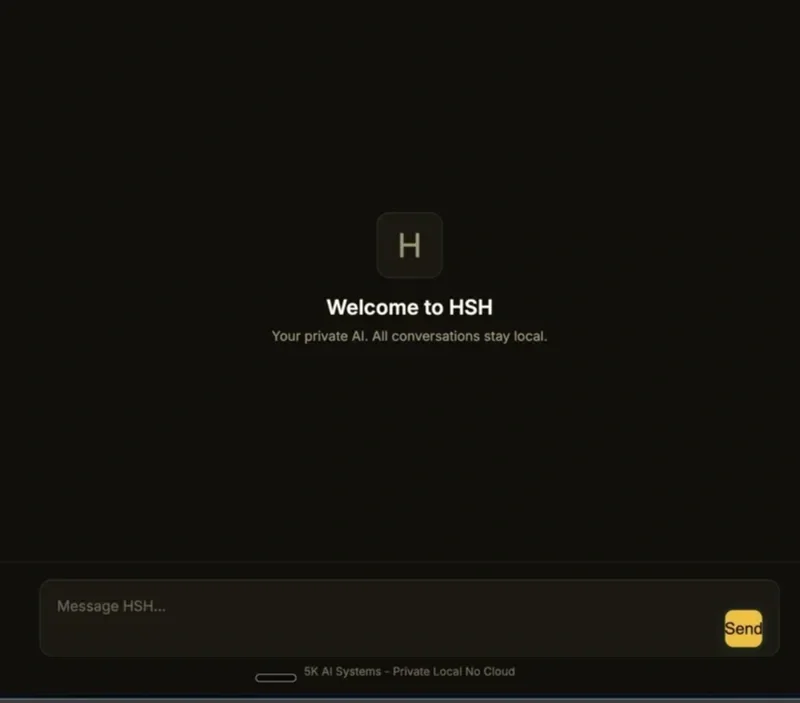
HSH(Home Sweet Home):
Local Jetson-based AI hub for teams and families. Multi-account, multi-agent, all private. No cloud. No data leaving your home.
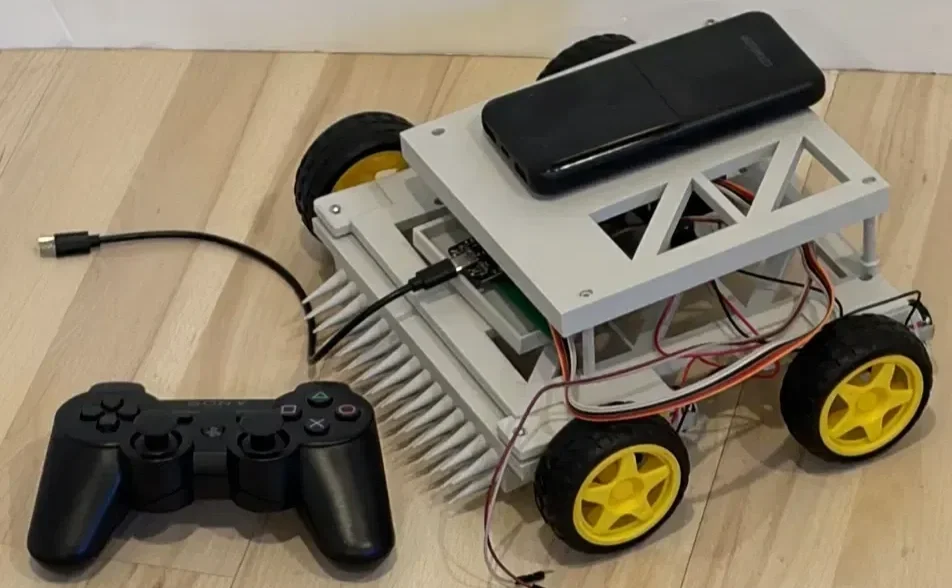
PS3 BOT V1:
PS3 controller-driven mobile robot built for robotics club. Tank-drive with Bluepad32 wireless—teaches motor control and gamepad integration.
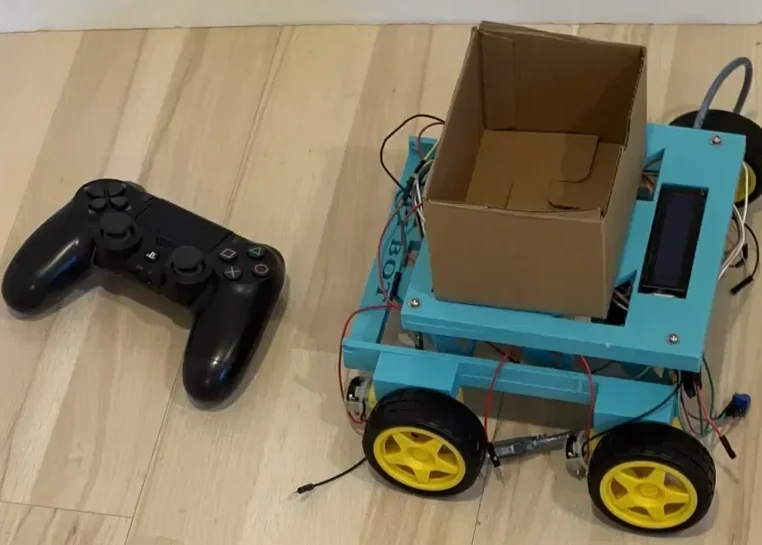
Fidget Bot:
Age 11 build. Raspberry Pi Zero with LCD that reacts to user input and dispenses 3D printed fidgets whilst being controller by a PS4 controller. Demonstrated at Maker Faire 2024 and 2025 as an accessible introduction to robotics and physical computing.
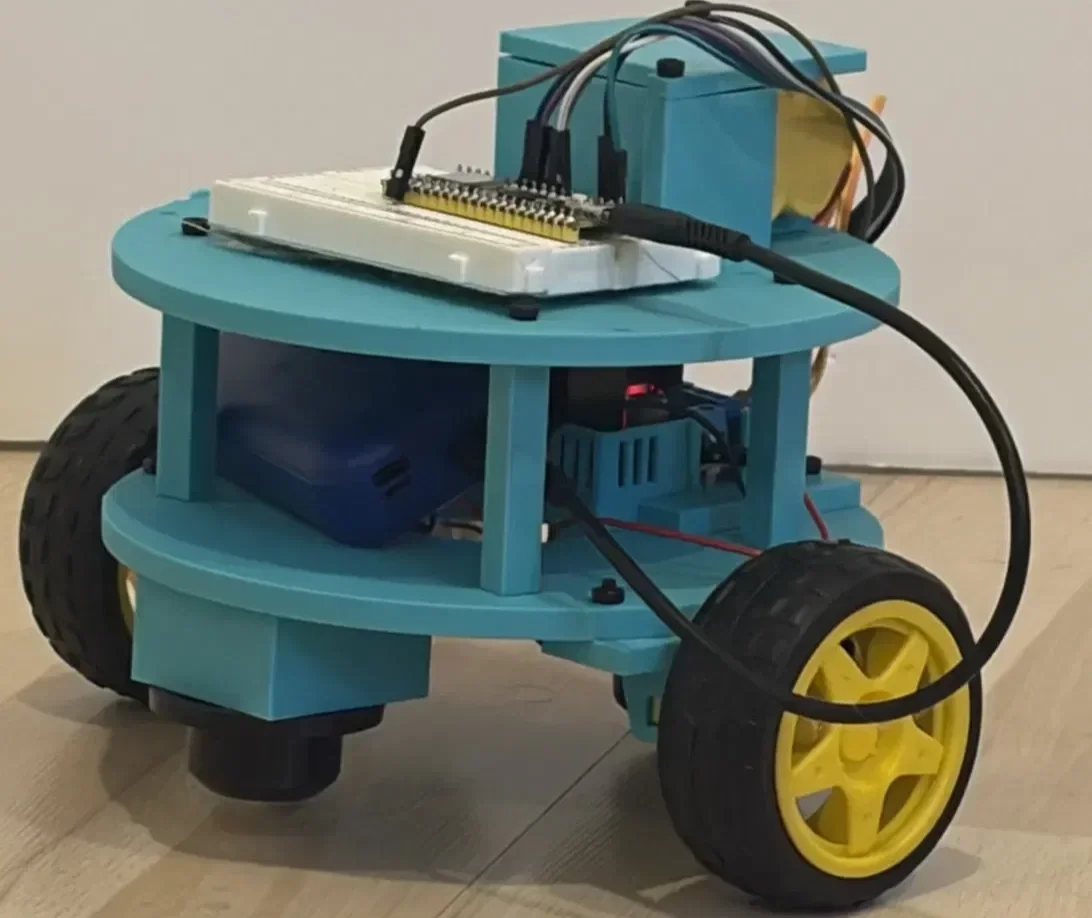
Camp Bot 2026 V1:
Pico W WiFi-controlled robot built for teaching kids robotics. Tank-drive platform with browser control interface—simple, reliable, educational.
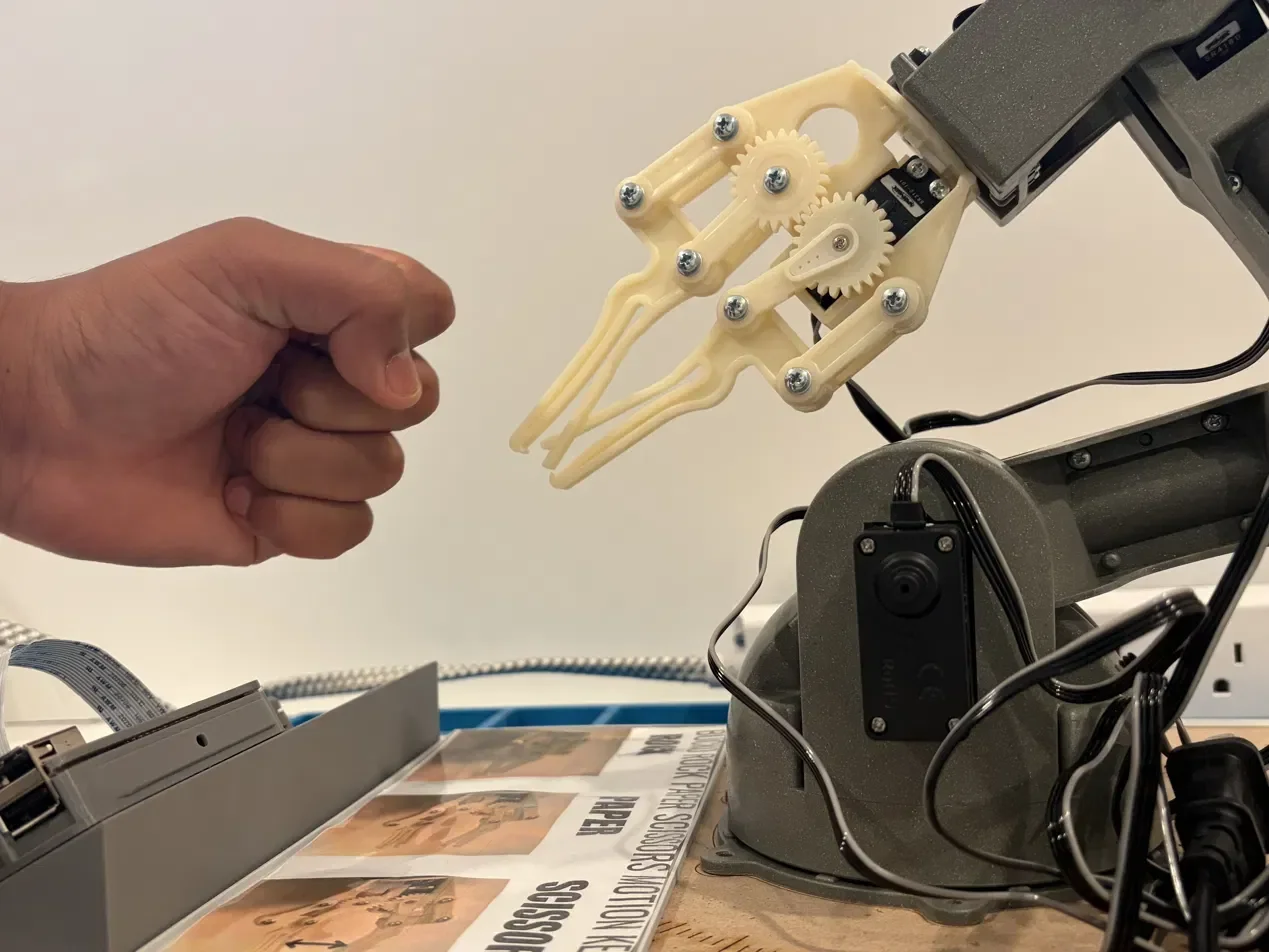
Bucko V1:
Braccio++ arm with MediaPipe vision that plays rock-paper-scissors. Detects your hand, always beats you. Built in 23 hours.
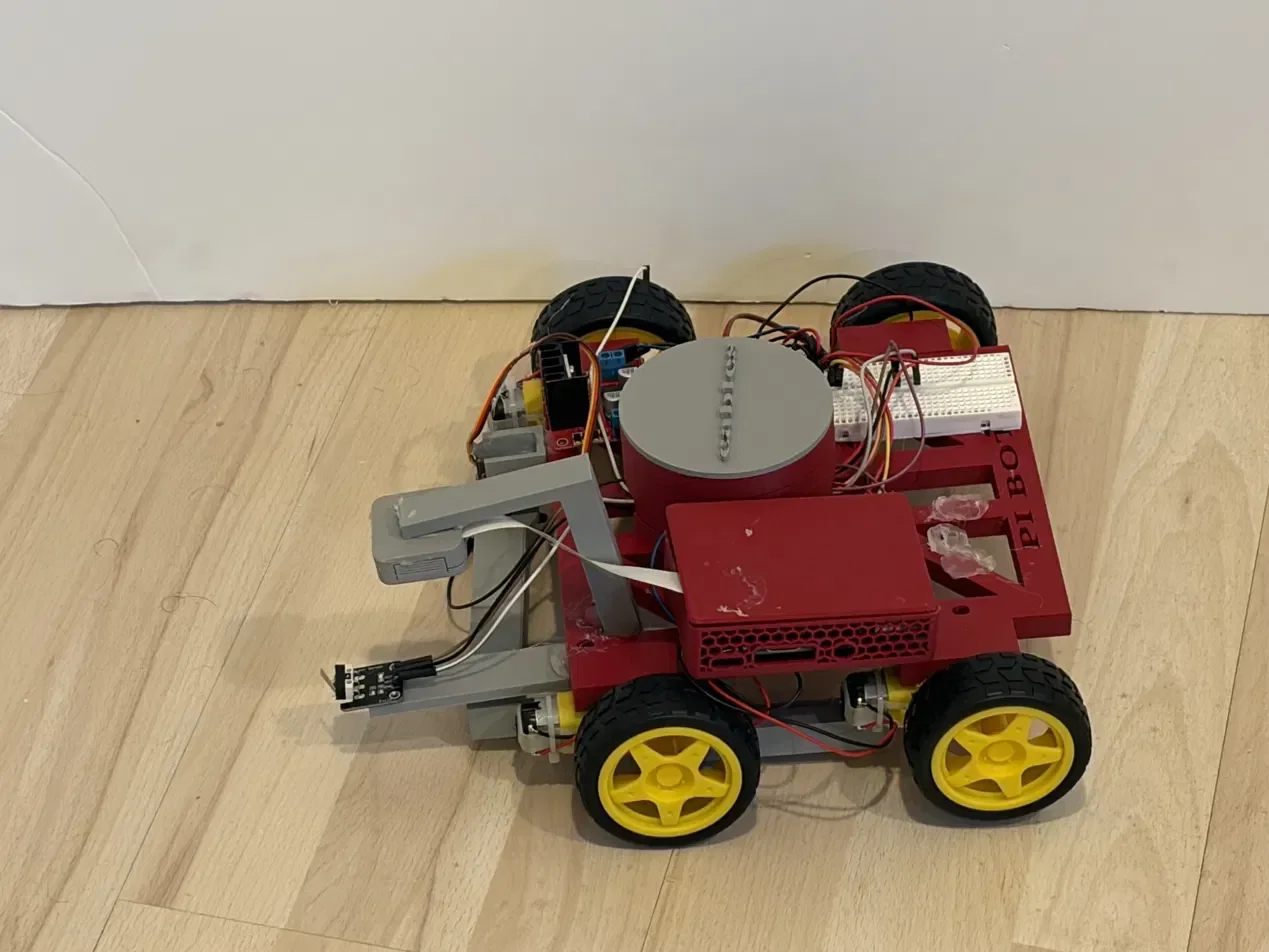
Picker Upper V1:
Age 12 project. Autonomous red-object hunting robot using YOLO detection with HSV/LAB/RGB color fusion for robust tracking. Servo-controlled gripper enables autonomous pickup behavior. You can stick red stickers to things that need to be picked up otherwise it does not go into the bin.It uses the Autonomous Navigator’s base as a way to navigate autonomously.
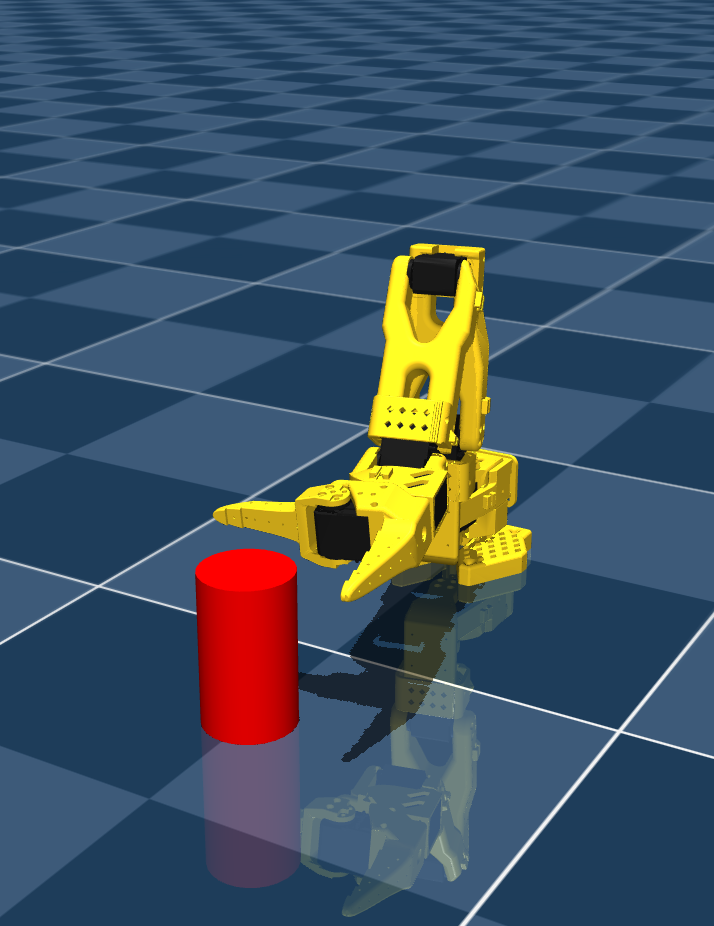
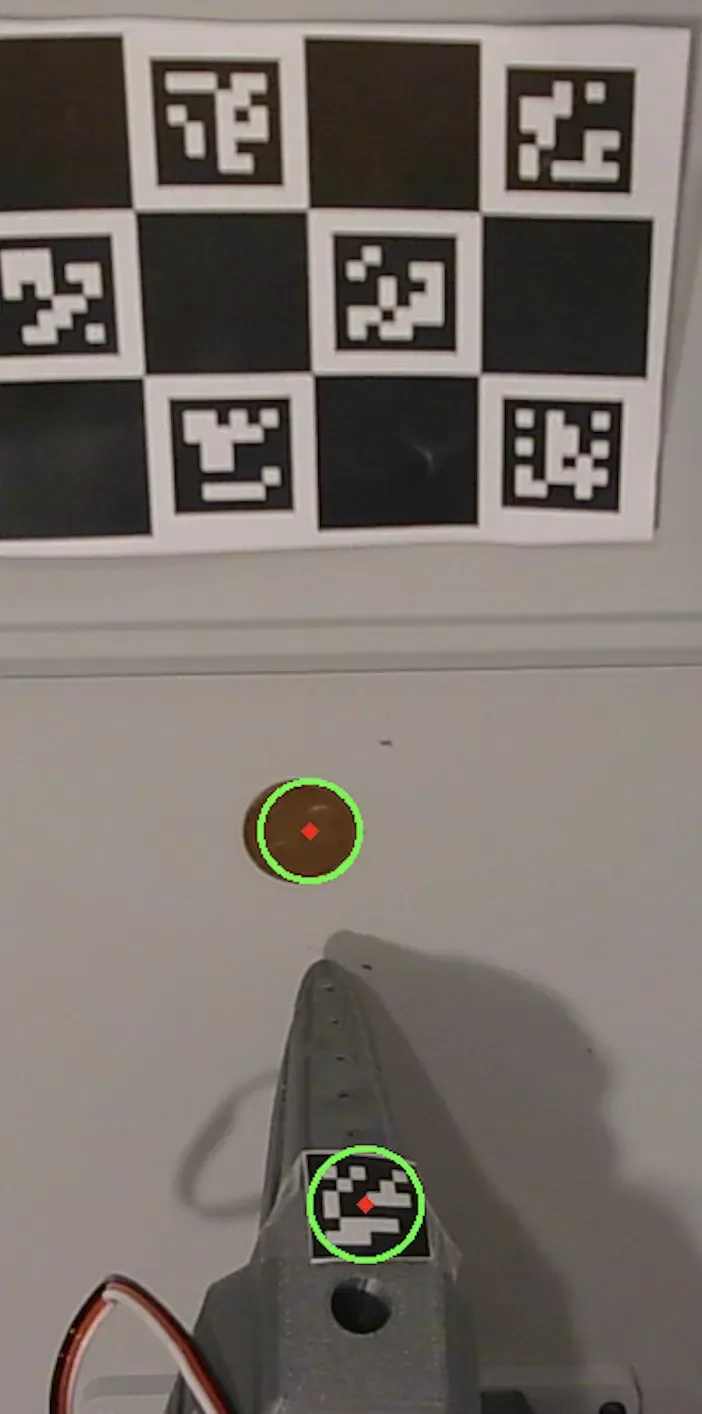
Sim 2 Real and Reinforcement Learning Research:
Trained reinforcement learning policy in MuJoCo simulation for object manipulation, then transferred to physical SO-101 arm. Proves sim-to-real transfer works for learned behaviors—no hand-coded inverse kinematics required, just trained policy.
Pretty Handy V1:
SO-101 arm that learns to pick up any object using only a camera and VLM—no training required. ArUco tracking + visual servoing = zero-shot manipulation.